Skip to content
    Axel Cuevas
    • Home
    • Blog
    • Projects
    • About
    • Resume
    🇺🇸
    Let's talk
    ← All projects01 / 12
    Case 01 · Rivero · 2026

    RIV-Scan — Pallet Dimensioner

    A depth camera, a Python point cloud, a pallet measured in under a second.

    StatusIn production
    RoleRivero
    Timeline2026
    CategoryHardware · Computer vision
    StackPythonOpen3DNumPyOrbbec ToFWebSocketsFastAPI
    LinksGitHub
    // riv-scan/cover.jpgBrief01/08
    // riv-scan/cover.jpg
    [00] Brief

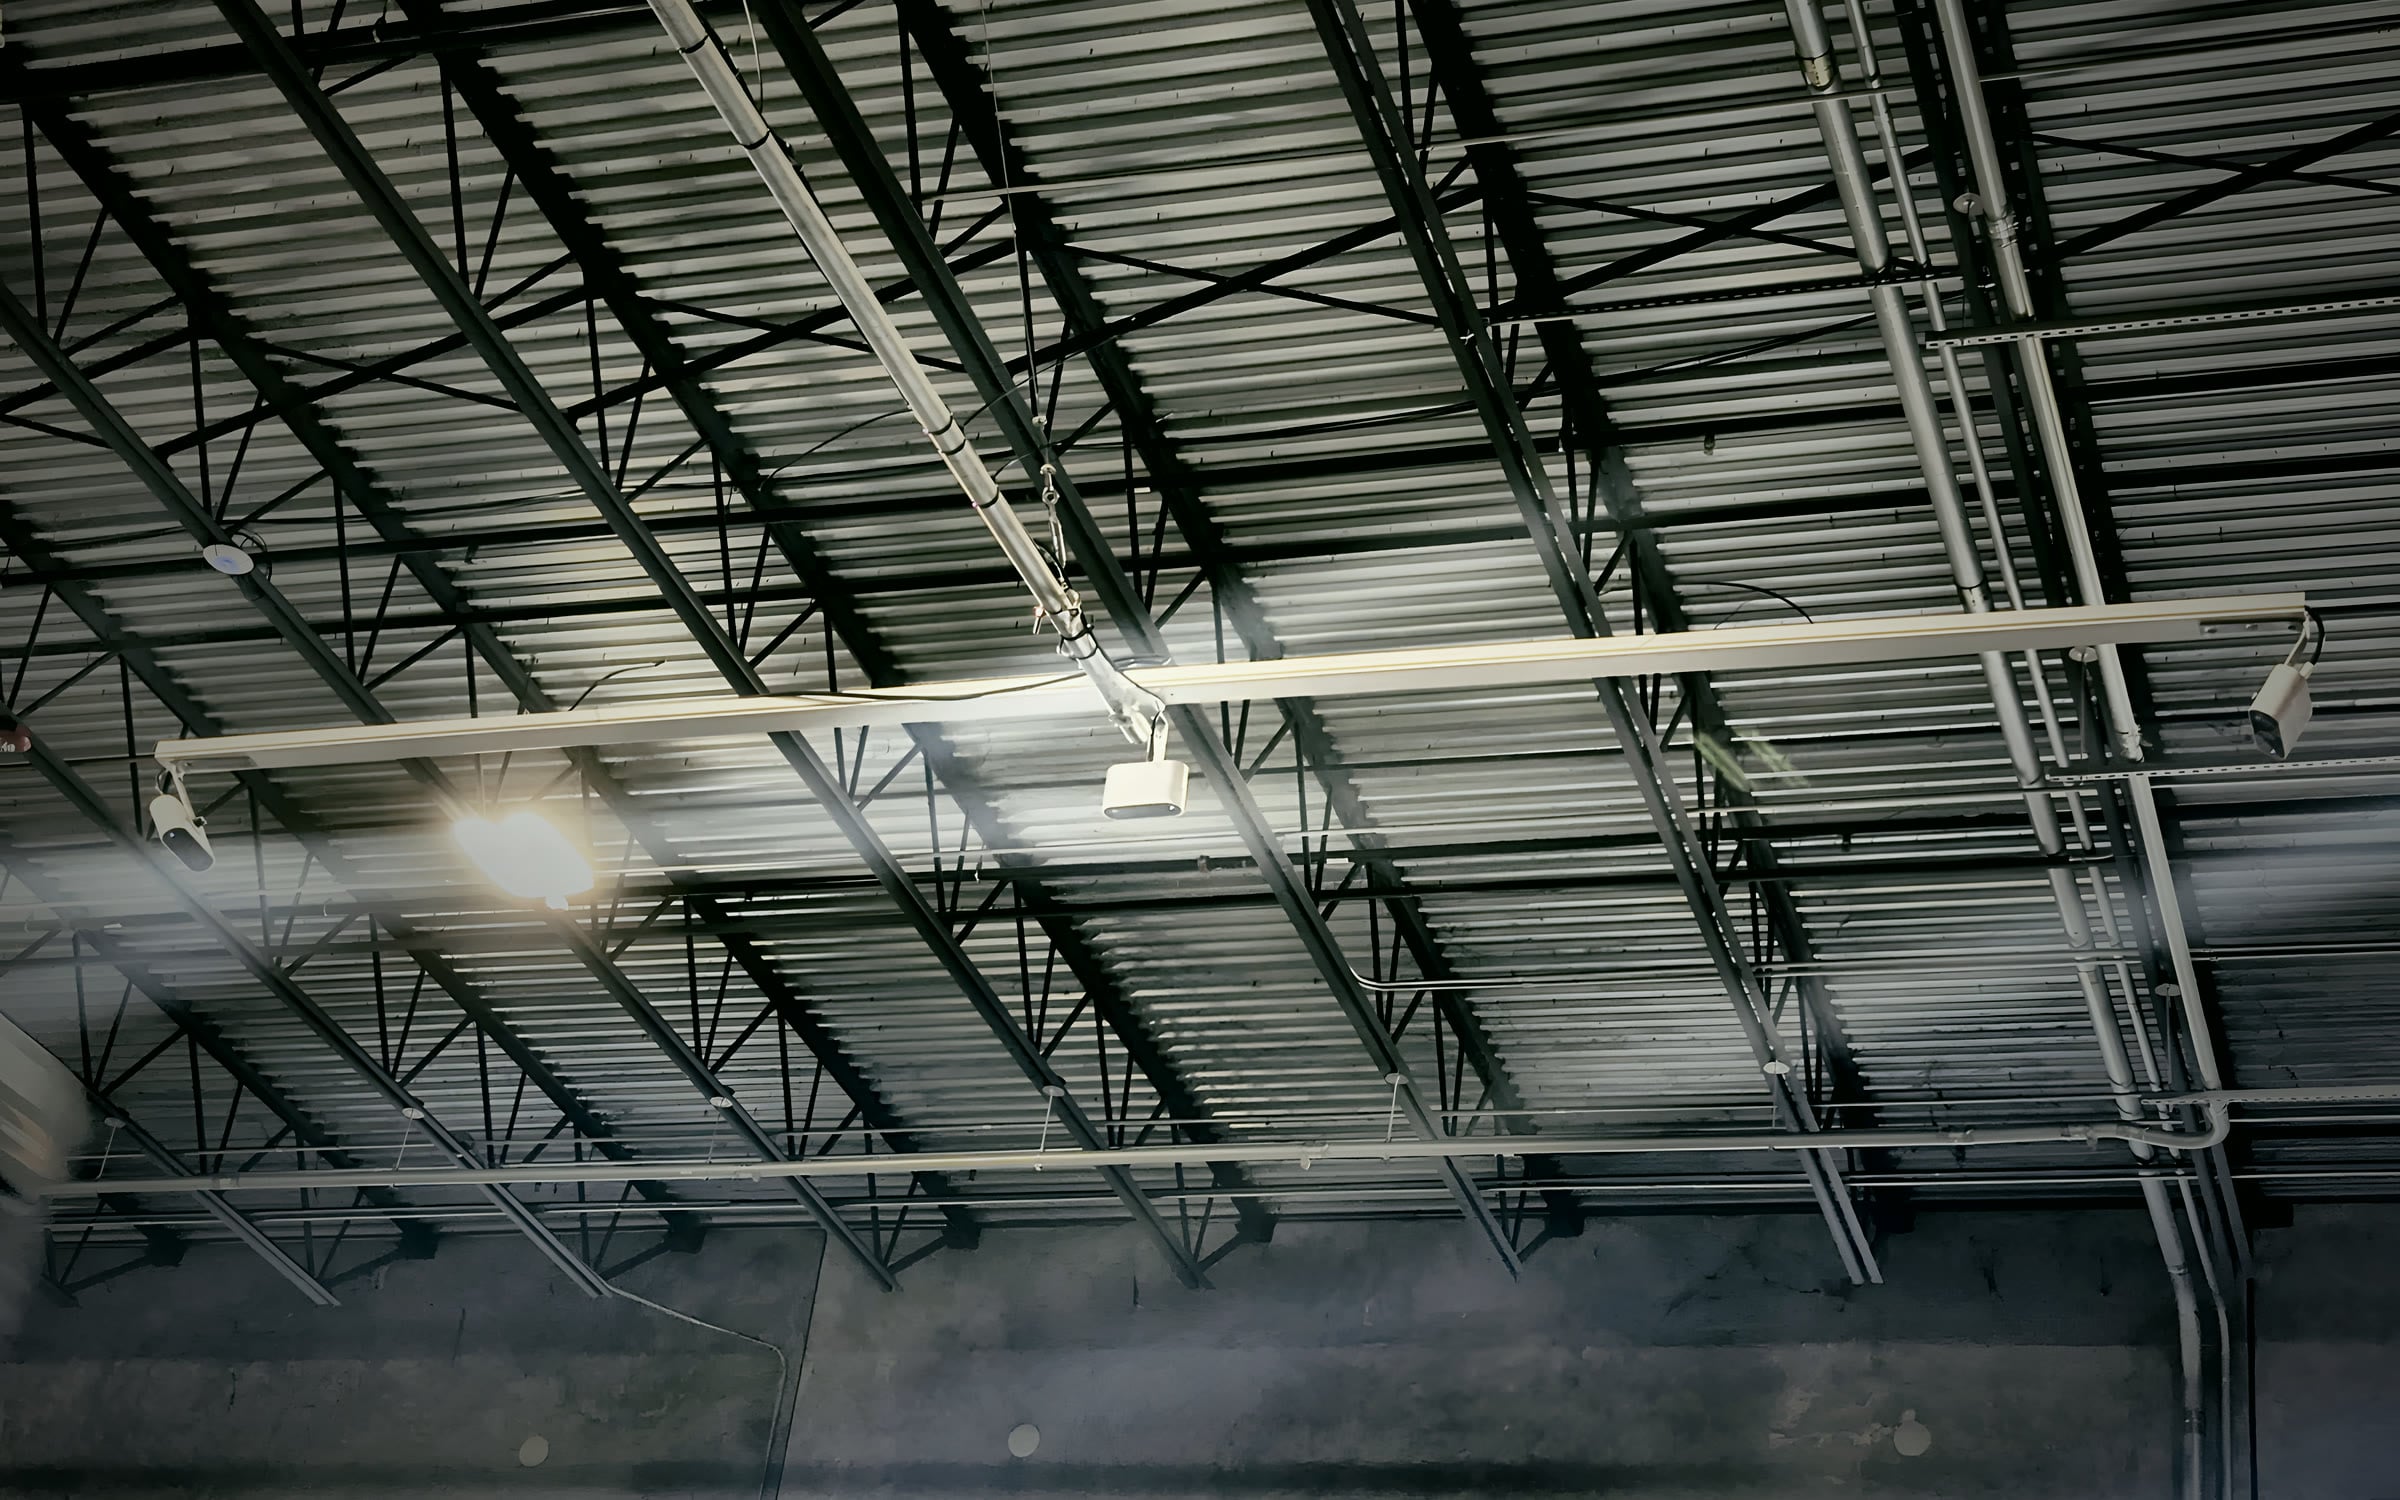
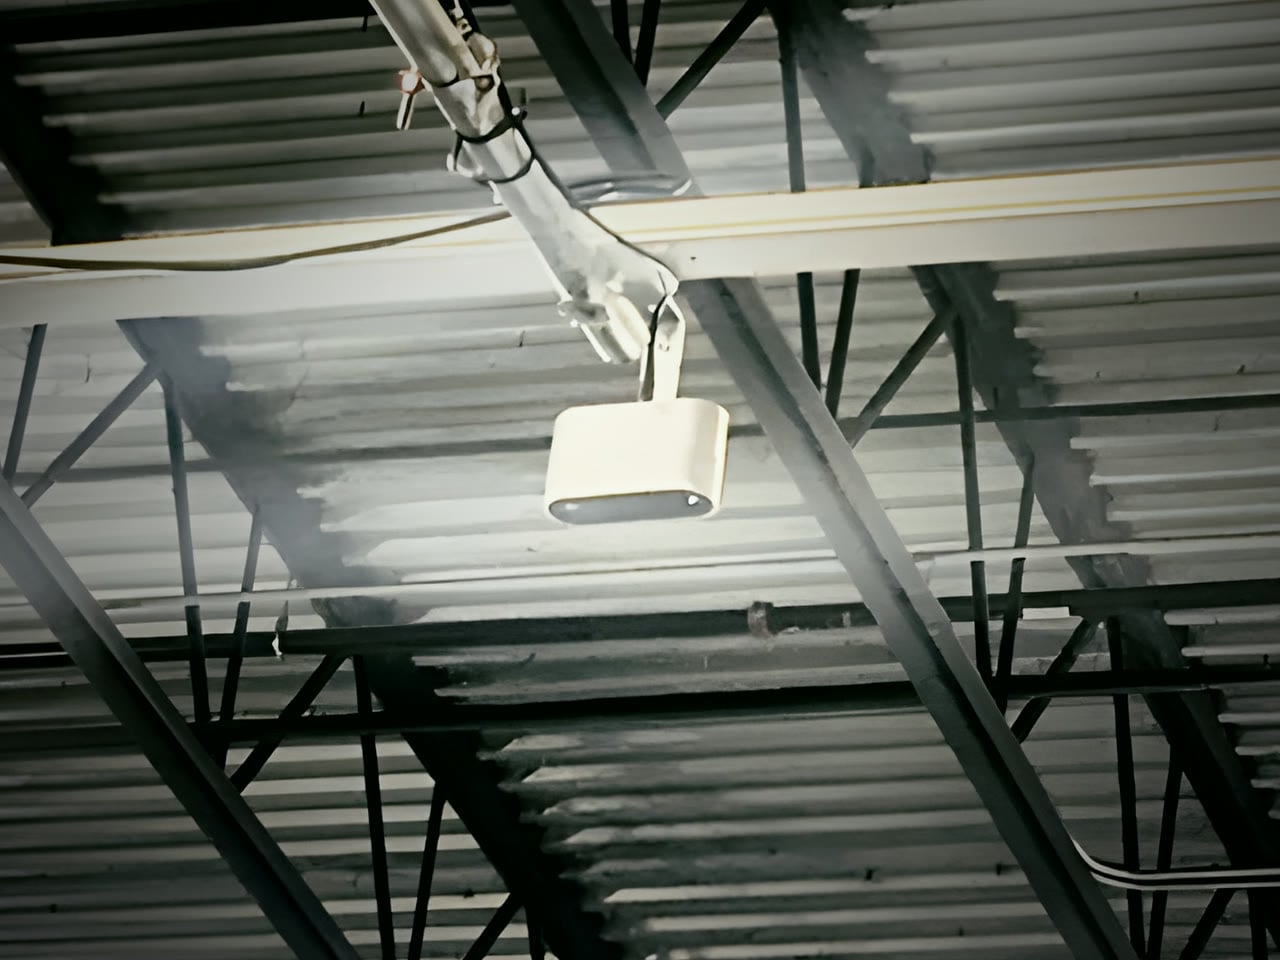
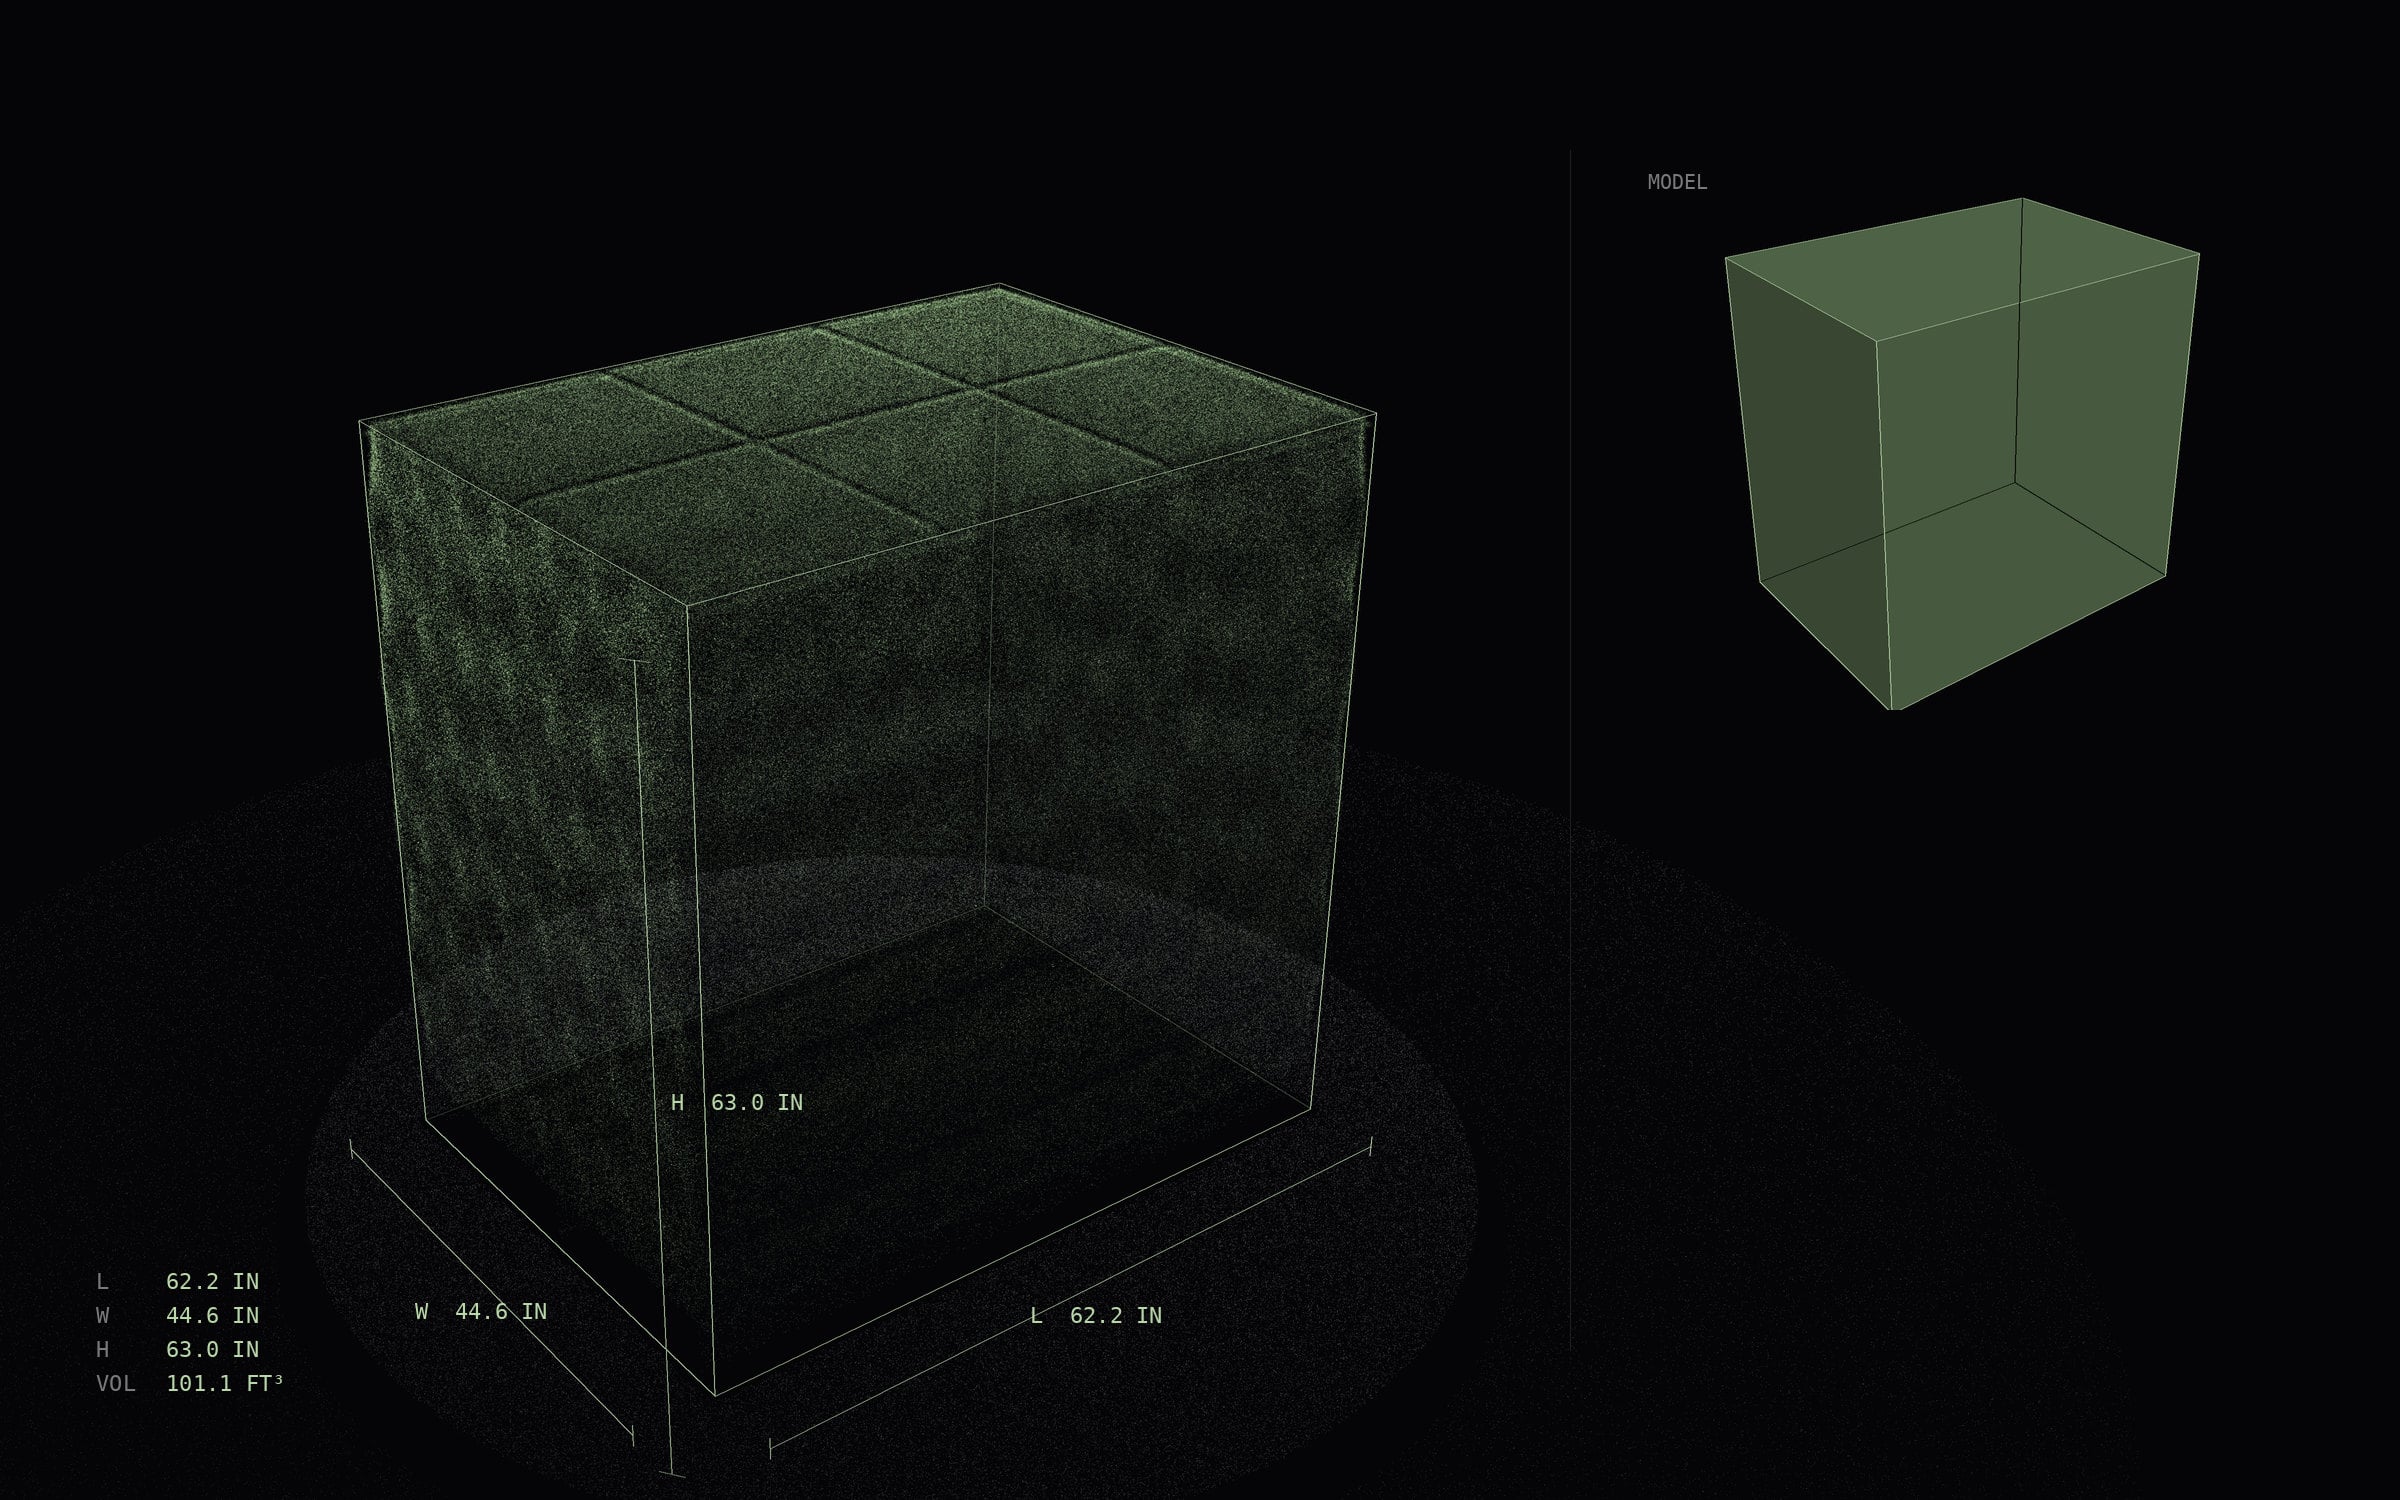
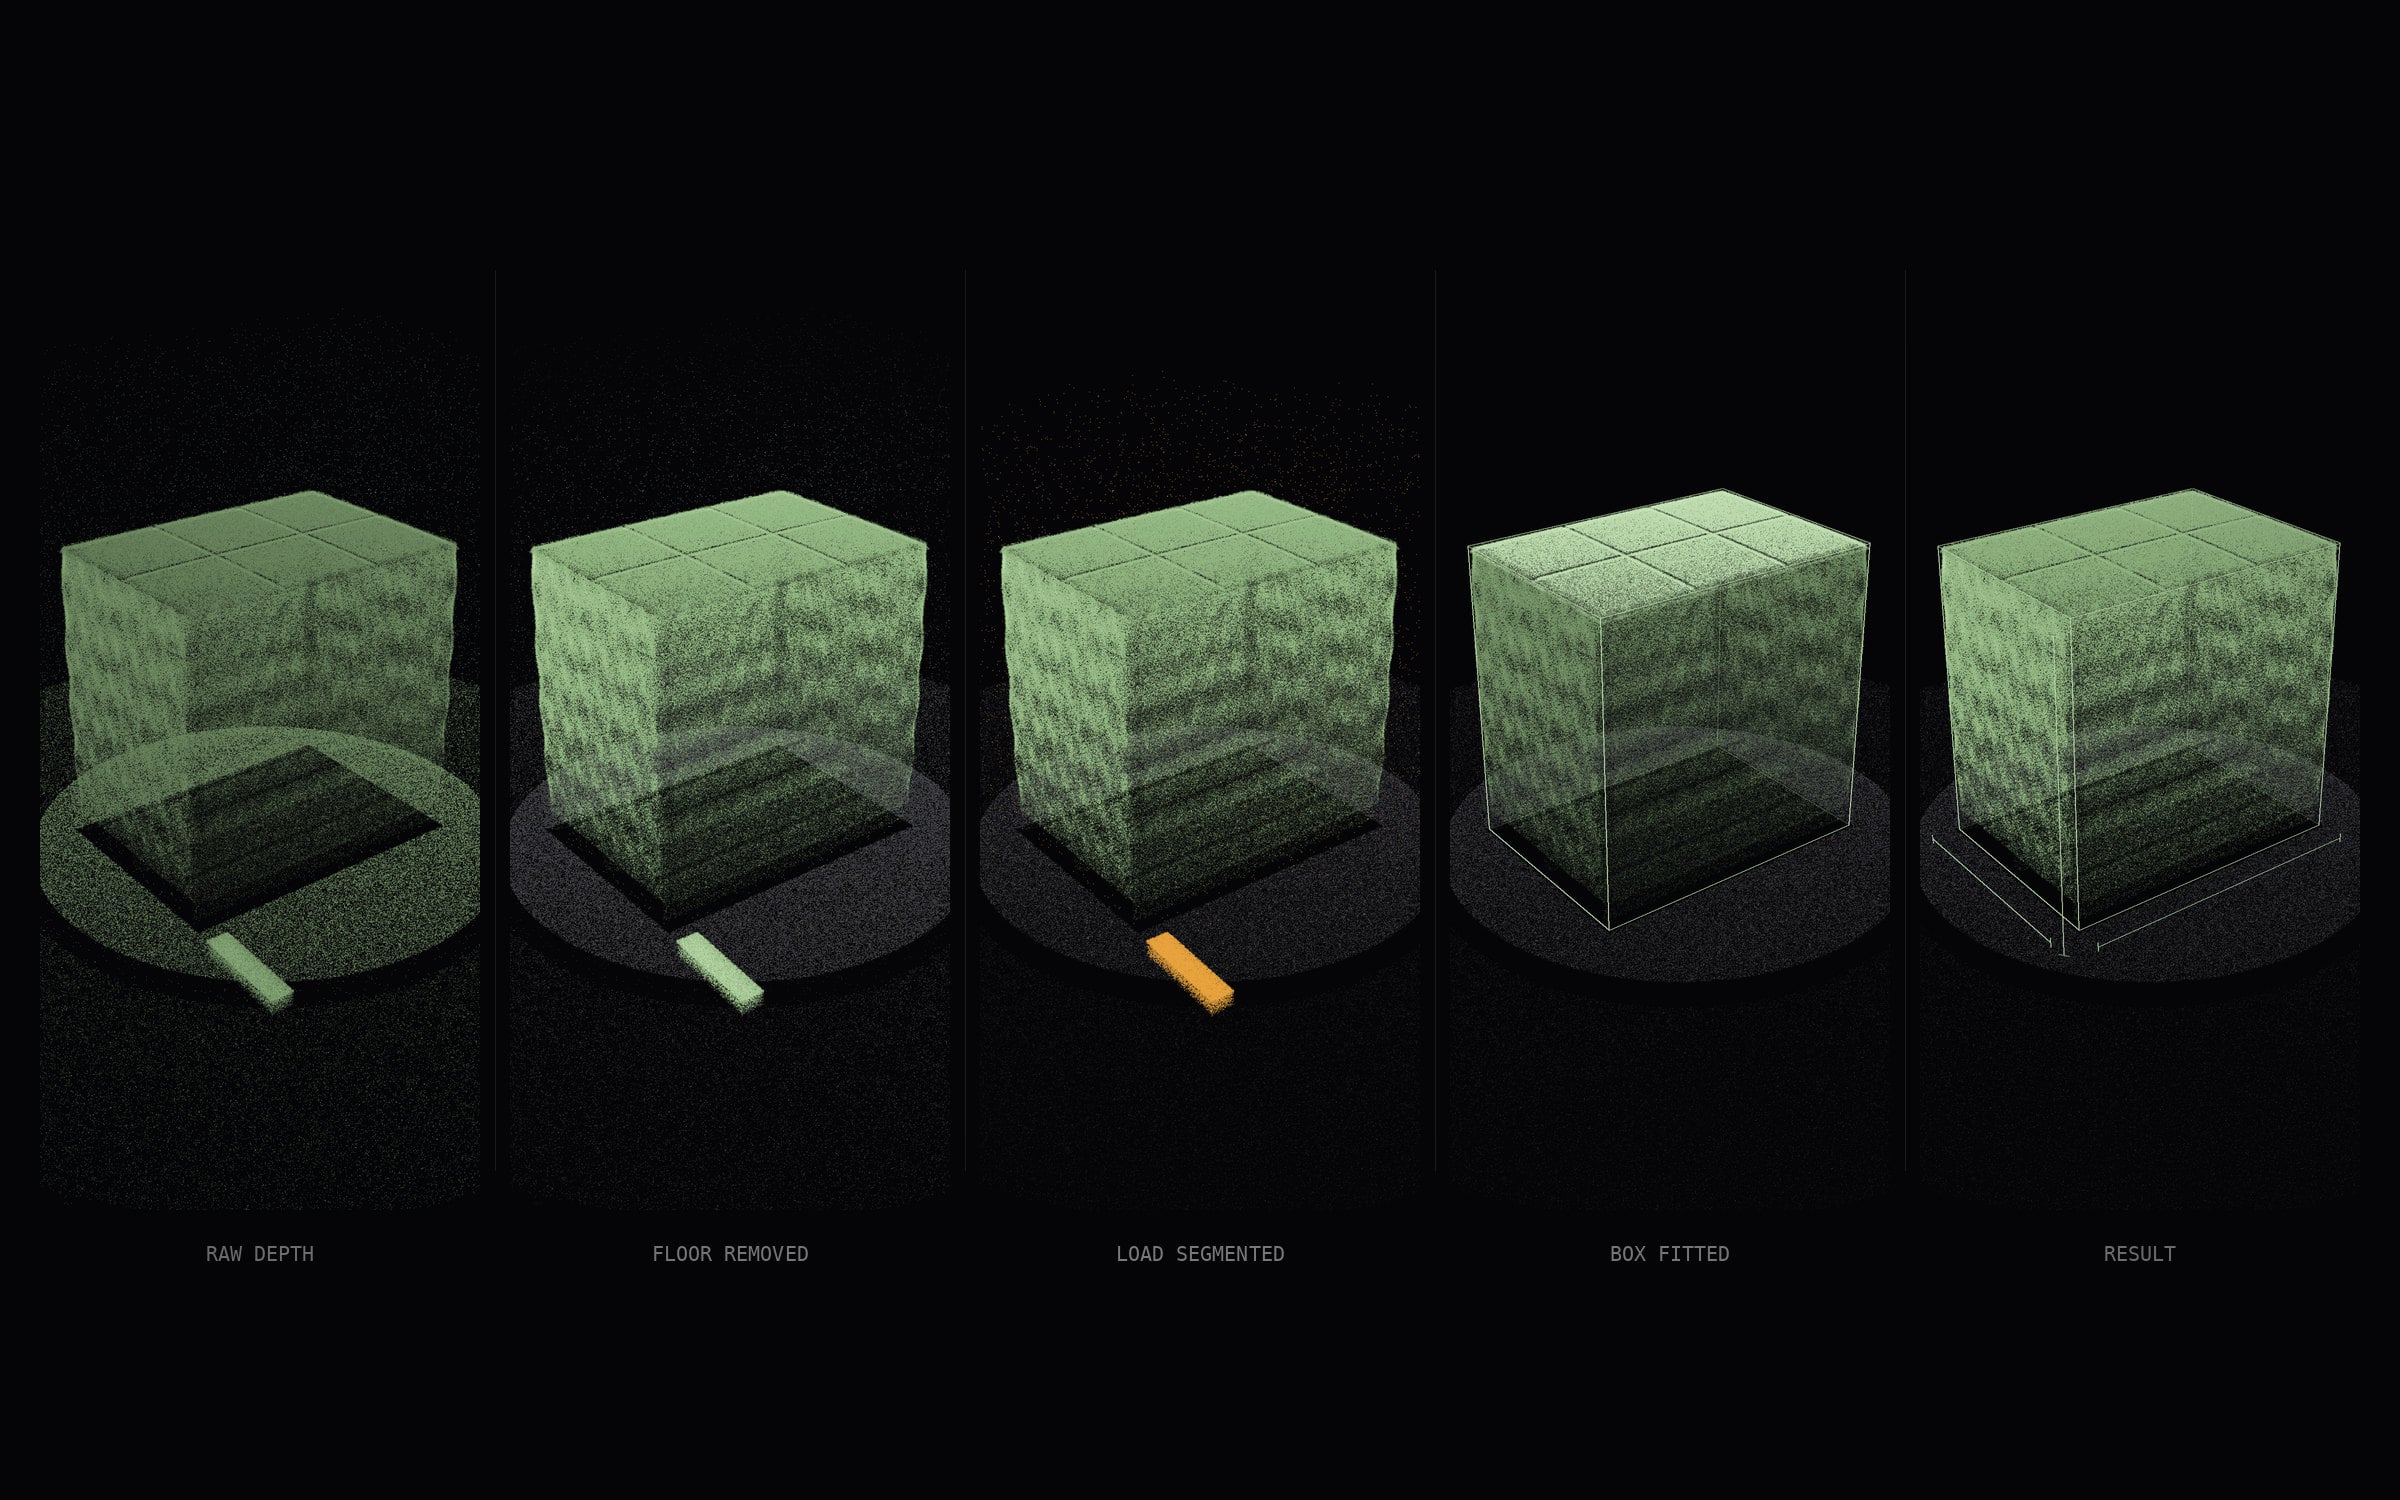
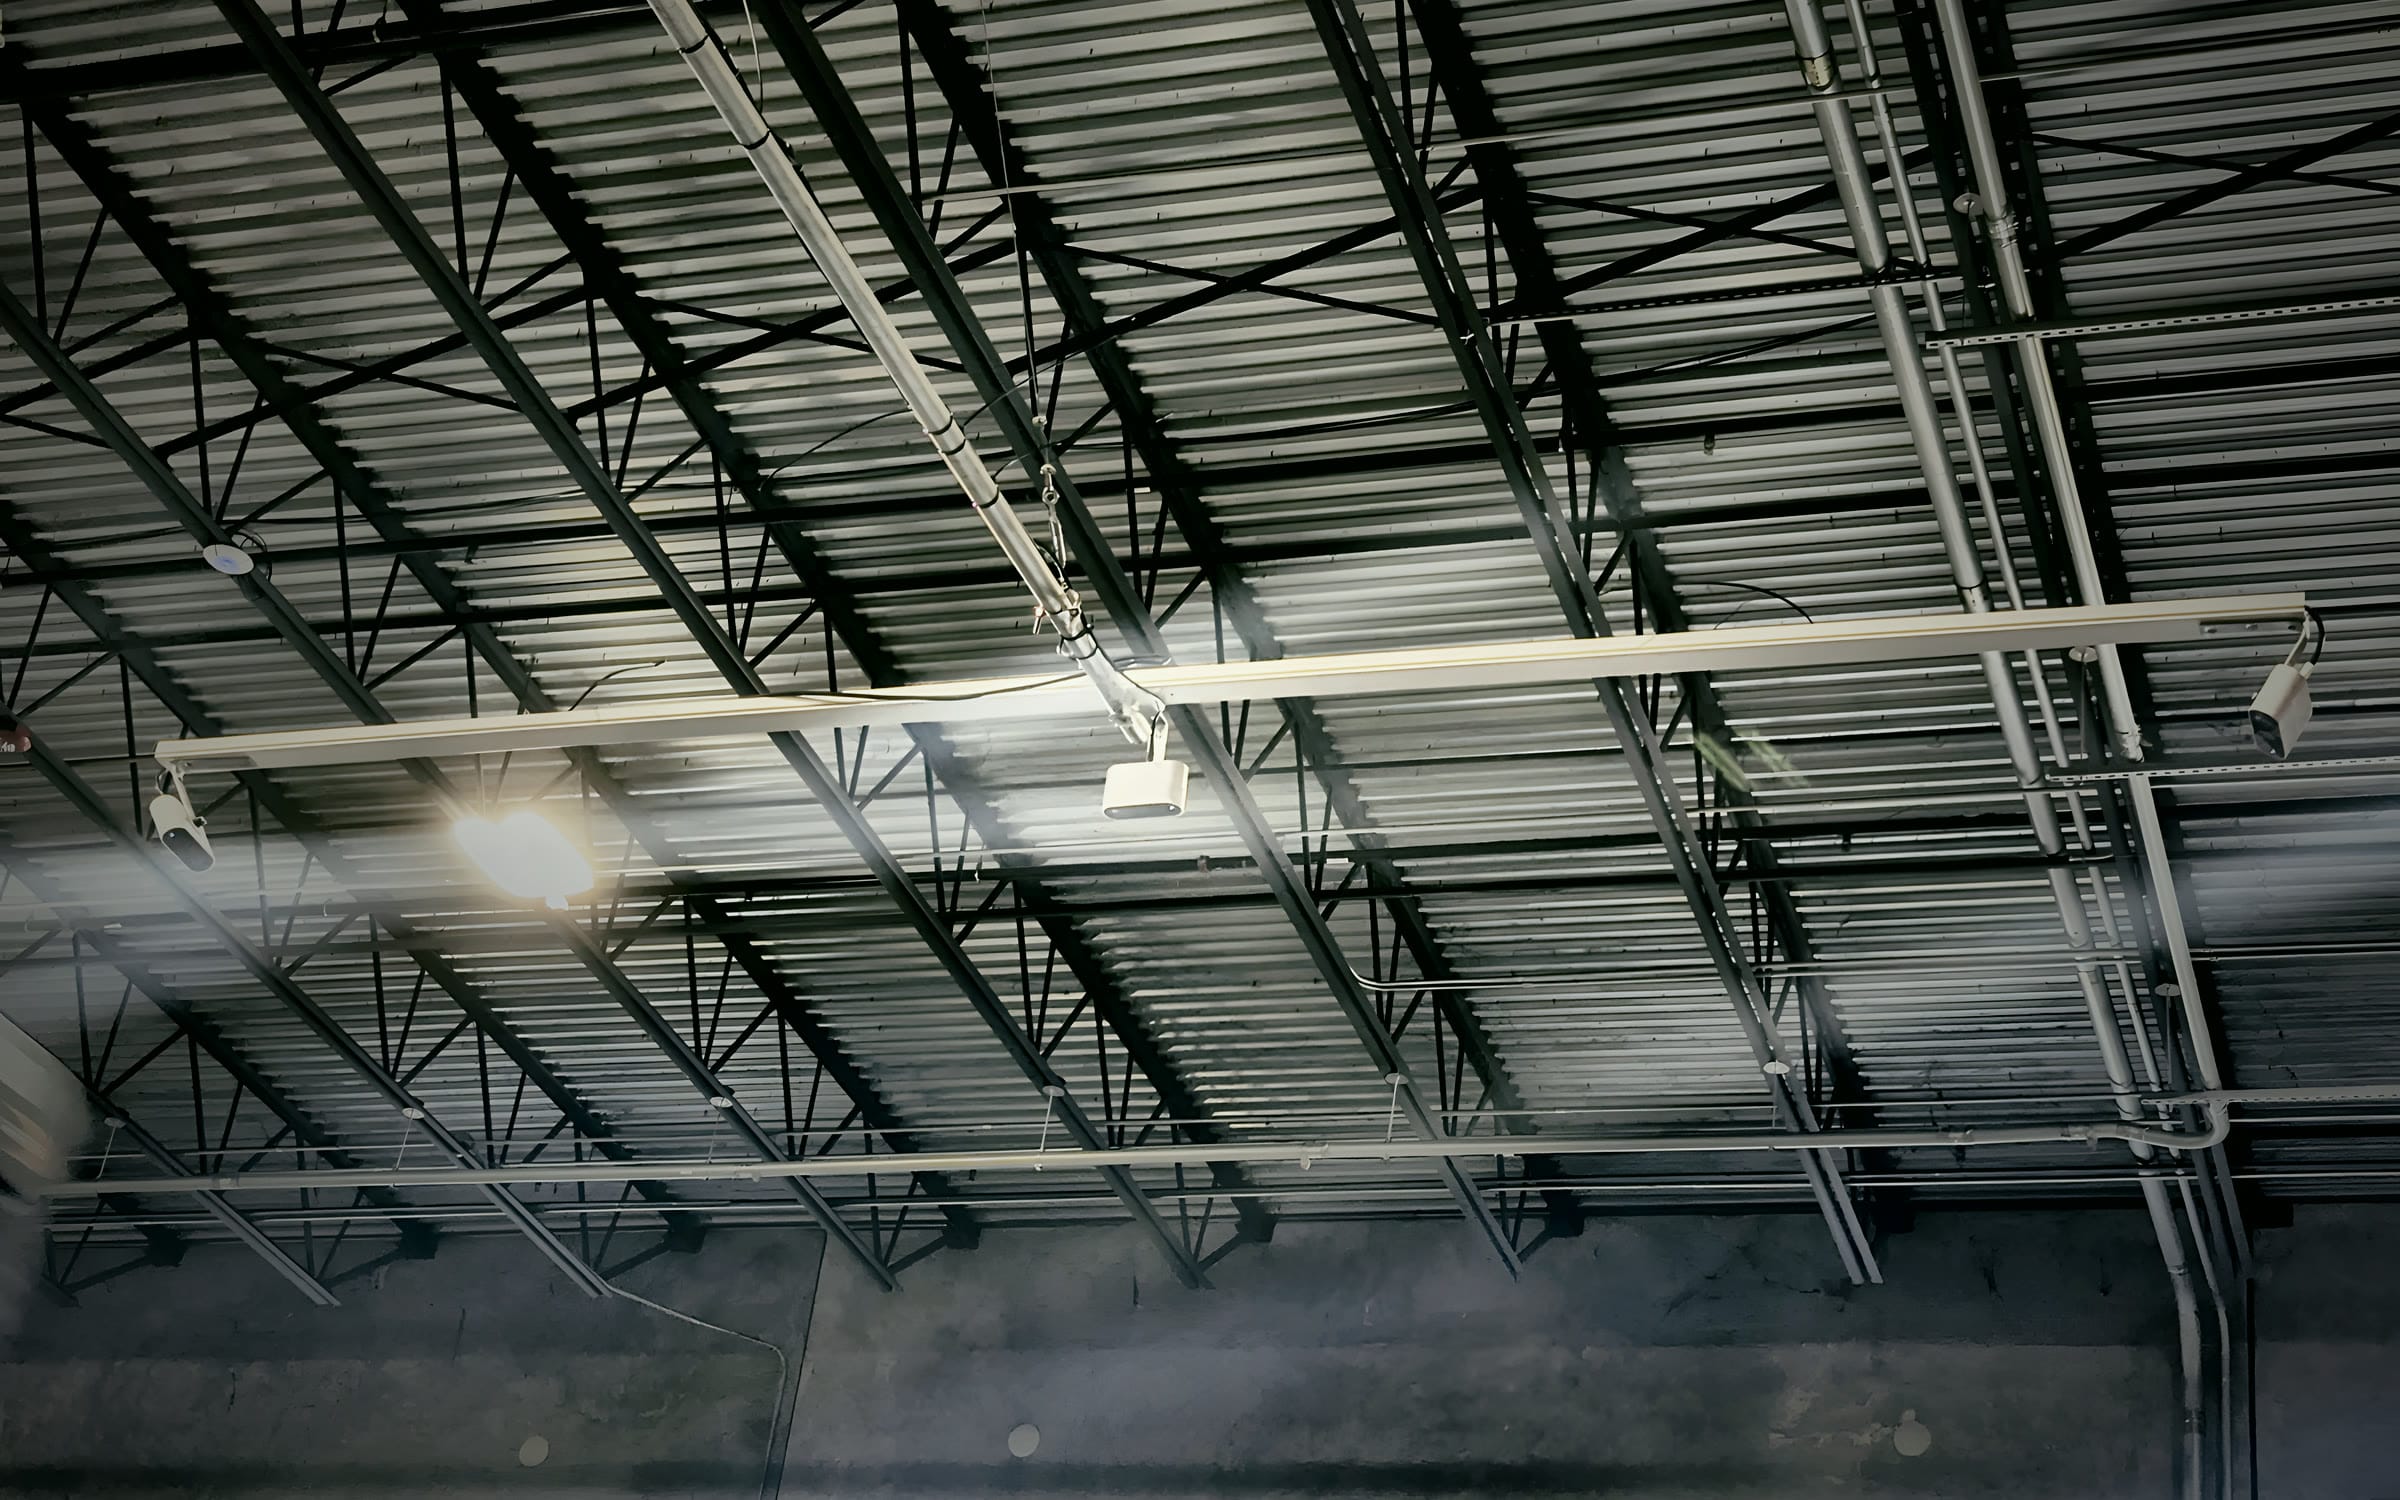
    A proprietary 3D pallet dimensioning station, hardware and software, built for Rivero's warehouses. Three Orbbec time-of-flight depth cameras feed a Python pipeline (OpenCV + Orbbec SDK) that pulls the pallet out of each point cloud, merges the views and returns length, width and height to the warehouse system over WebSockets. About $3,500 in hardware against roughly $25k for a commercial station, designed to work differently from a competitor's US patent, and it drew B2B licensing interest from the country's largest supermarket chain.

    // riv-scan/reconstruct-tall.mp4
    [01] Problem

    Every pallet at Rivero was measured by hand before it was stored or shipped. It was slow and the numbers were often wrong. Commercial dimensioners cost around $25k per station, and the leading vendor sits on a US patent, so nobody wanted to buy more than one.

    // riv-scan/reconstruct-tall.mp4
    [02] Build

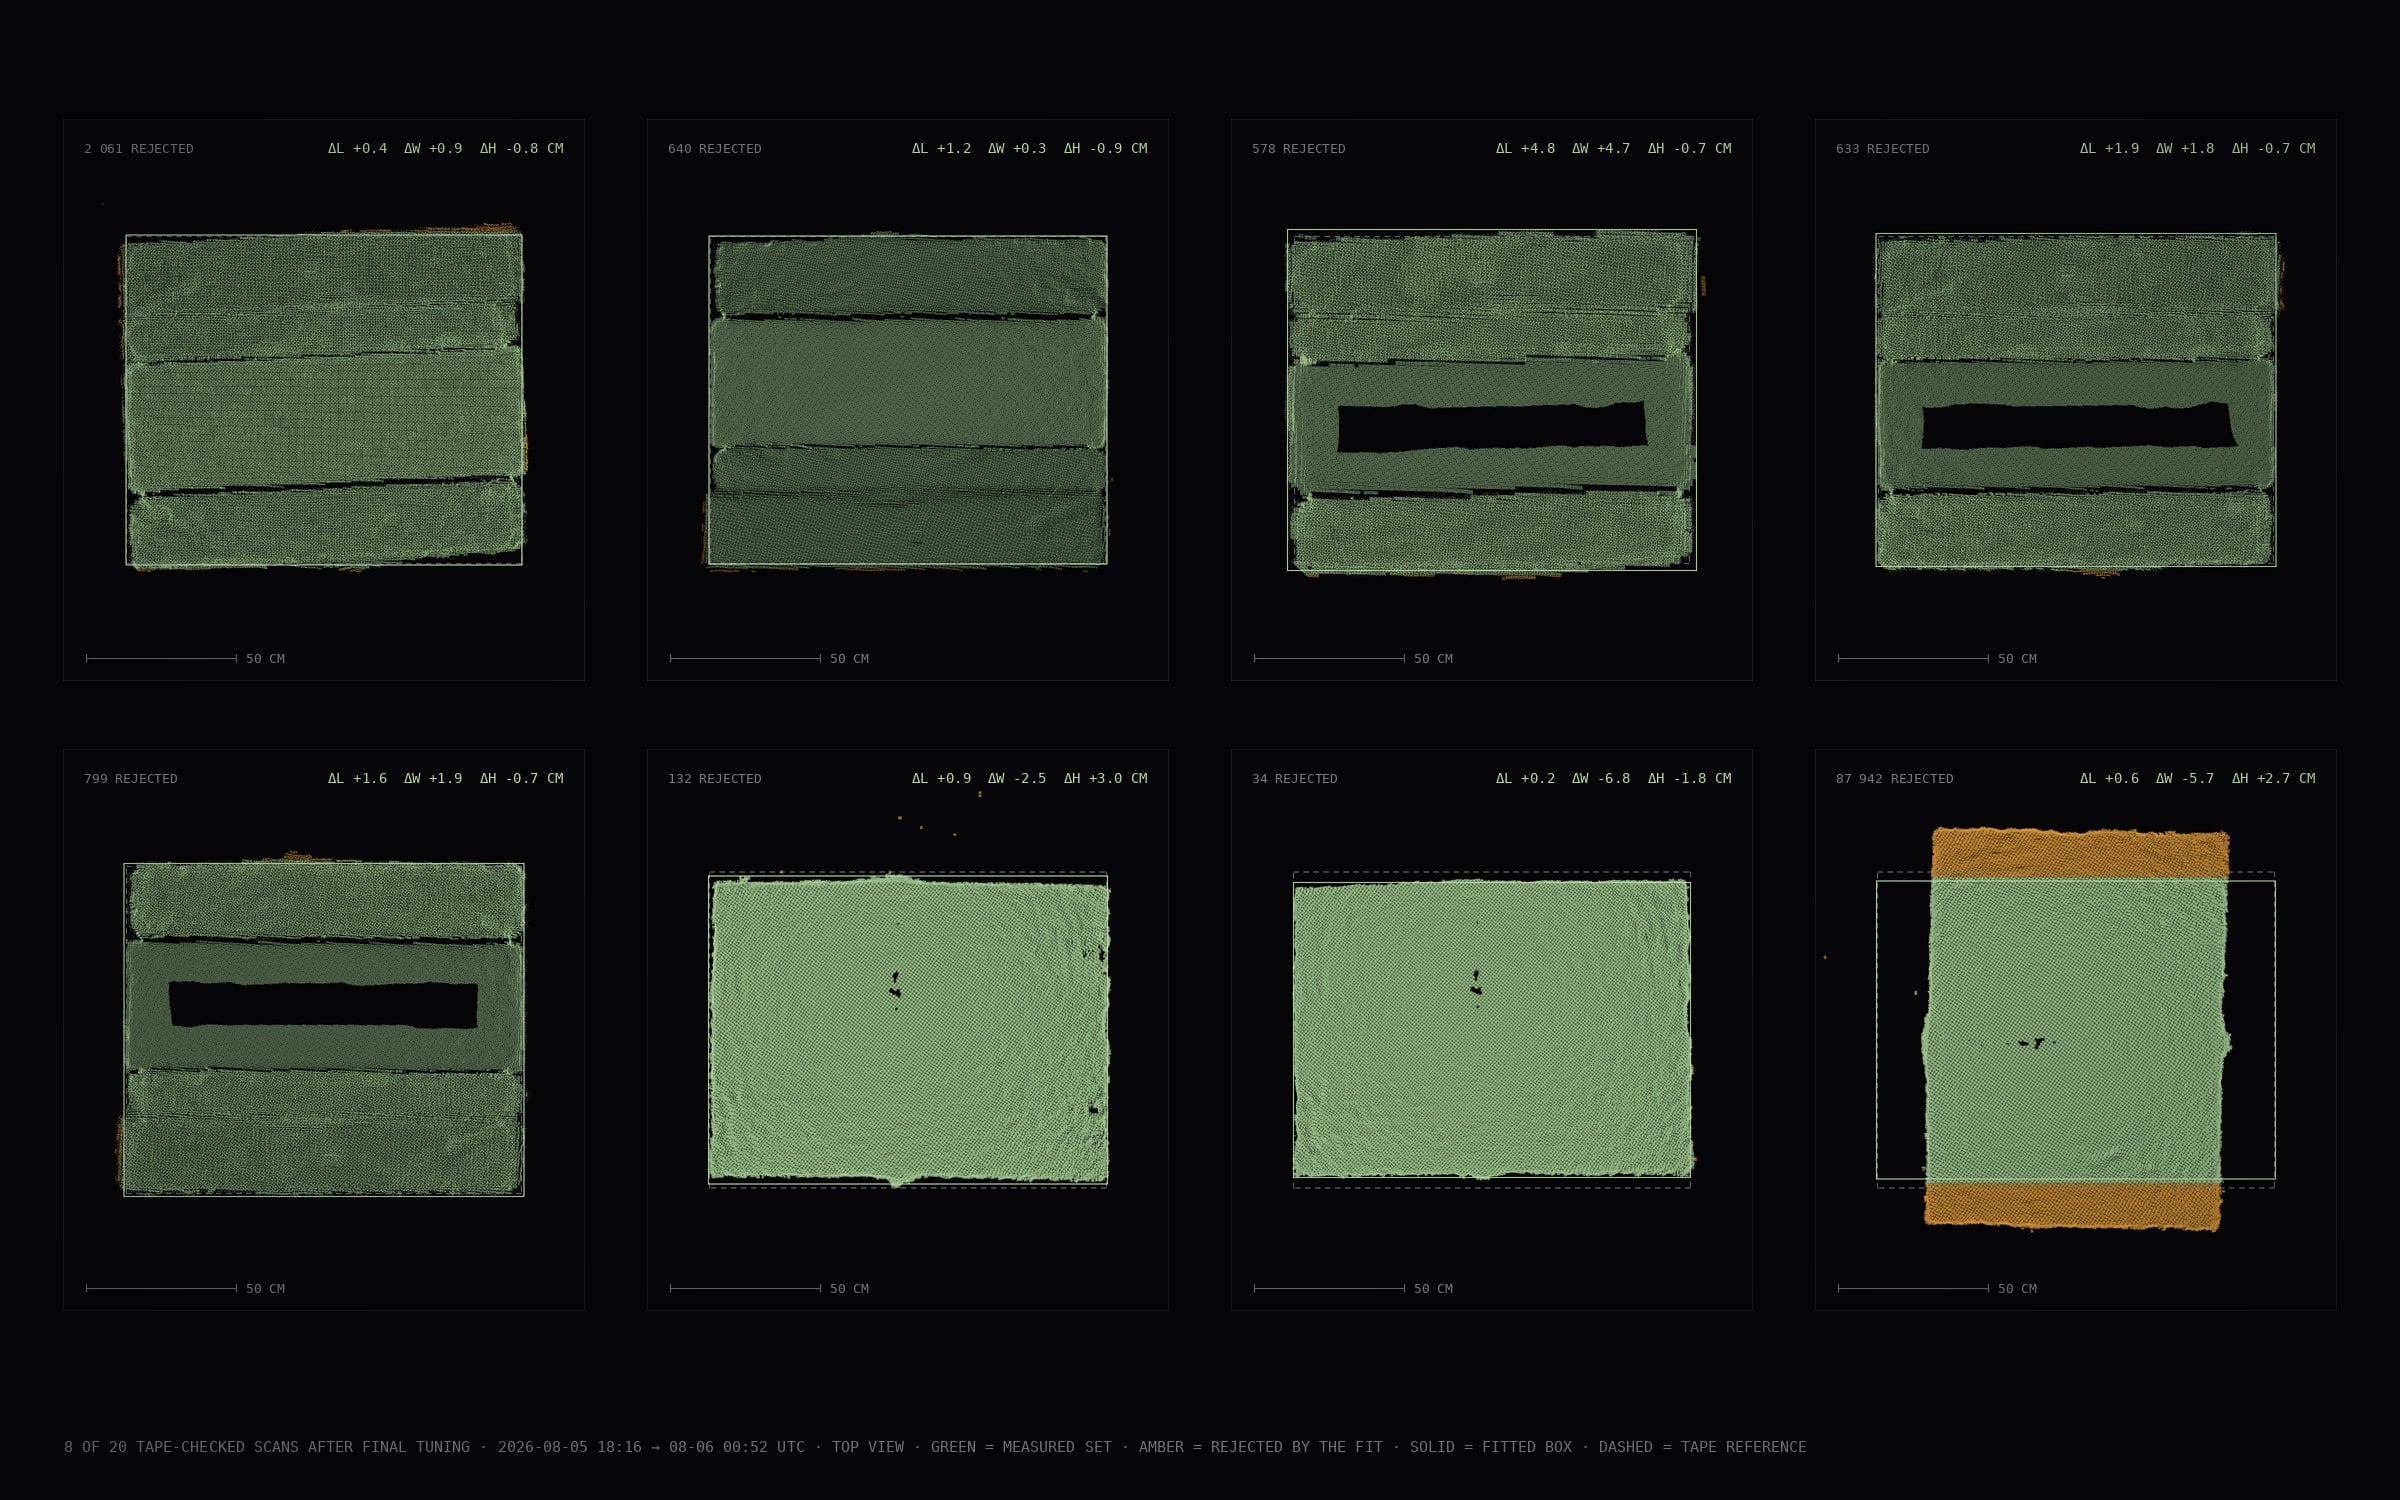
    I pitched building our own, did the plan and the budget, and owned it end to end: hardware, software and bringing in the people to build the rig. Three Orbbec ToF cameras feed a Python pipeline (OpenCV + Orbbec SDK) that pulls the pallet out of each point cloud, merges them and computes length, width and height, then streams the result over WebSockets into the WMS so the operator sees it the moment the pallet is in place. The approach works differently from the patent, so we could use it and sell it. I had never worked with computer vision before this, so I tuned the detection in a tight feedback loop with Claude: it got the camera's debug outputs, a merged point cloud, photos from different scenarios and 120+ pallets I measured by hand, and the algorithm was tested against that data over and over until the error was down to ±0.3 in. It felt like fine-tuning the algorithm at a higher level of abstraction.

    PythonOpen3DNumPyOrbbec ToFWebSocketsFastAPIDocker
    // riv-scan/wms-tall.mp4
    [03] Result

    A pallet is measured in under a second, on about $3,500 of hardware instead of a $25k station. The measurements and 3D models ended up going on the e-commerce page, which made our customers more money, and they cut our operating costs because we could put pallets away on the racks more efficiently and plan truck loads better. The DR's largest supermarket chain asked about licensing it.

    $25k+
    saved per station
    <1 s
    per pallet
    1
    US patent bypassed by design
    Next case

    Orchy — Permission-Gated AI Orchestrator

    All projects
    02Rivero · 2026

    Orchy — Permission-Gated AI Orchestrator

    An agent that runs backend operations from Slack, and can only touch what it was allowed to.

    ← Previous: Paycom - Minimalist Payroll SystemSelected work
    Contact

    Have a system that needs building?

    axeljcuevast@gmail.com
    Santo Domingo · · open to select freelance
    Keep exploring
    AboutWho I am and how I workProjectsCase studies, systems and codeResumeExperience, stack and CV
    © 2026 Axel CuevasGitHub · LinkedIn · X · Instagram · CVBuilt with Next.js · three.js · GSAP